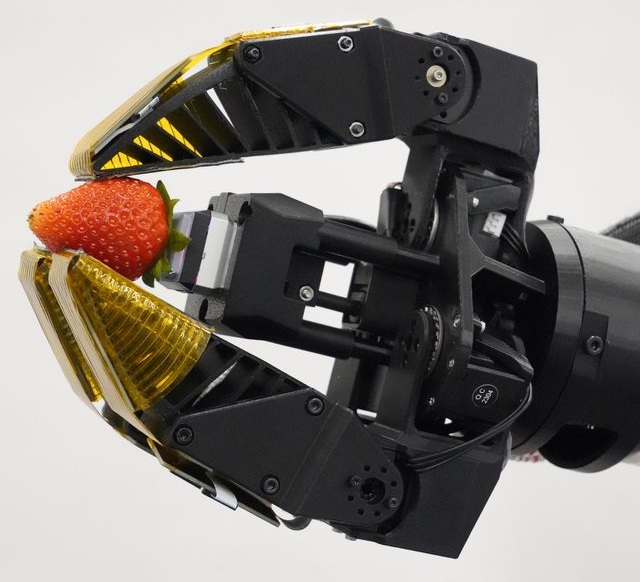
Improving Robotic Gripper Manipulations and Assessments
Robotic grippers, known as end-effectors, have widely varying architectures and functionality. These variations enable grippers to be used in industrial, life science, and medical environments among others.
Purdue researchers have developed patent-pending innovations to strengthen the ability for grippers to manipulate and assess objects in unstructured or variable environments.
solution 1
Researchers have developed a gripper with a tactile-responsive palm and compliant, sensor-enabled fingers. It distributes perception and actuation across the palm-finger system to improve adaptability and contact-rich manipulation.
This Purdue gripper provides reliable, informed grasping without increased mechanical complexity. Manufacturers and robotics integrators benefit from improved handling consistency and less need for highly specialized grippers.
Researchers evaluated a prototype gripper across standard benchmarks and varied manipulation scenarios. Results show improved responsiveness and dexterity compared to traditional low degree-of-freedom grippers.
solution 2
Researchers have developed and validated a soft pneumatic gripper that integrates tactile perception and object manipulation without rigid sensors or fixed contact pads.
Unlike traditional planar tactile sensors, this Purdue gripper uses flexible fiber elements embedded within a soft structure to provide responsive, geometry-aware feedback.
Testing shows that the gripper recognizes diverse object types and operates across air and water settings. This positions the technology as a pathway for more adaptive, versatile robotic end-effectors.
Industry partners interested in developing or commercializing the innovations should contact Jacob Brejcha, Licensing Associate, Physical Science, jjbrejcha@prf.org.